"Imagine that there's a disaster scenario, flooding, or an earthquake, and we want robots to aid humans in the search-and-rescue process."
Pulkit Agrawal, MIT professor, CSAIL principal investigator
MIT researchers have developed a four-legged walking robotic system, or quadruped robot, that can dribble a soccer ball on different natural terrains. The system, called DribbleBot, uses a reinforcement learning approach to learn how to dribble by receiving a reward when it succeeds and negative reinforcement when it fails. The robot also uses onboard sensing and computing to navigate unfamiliar terrains and recover from falls using a recovery controller built into its system.
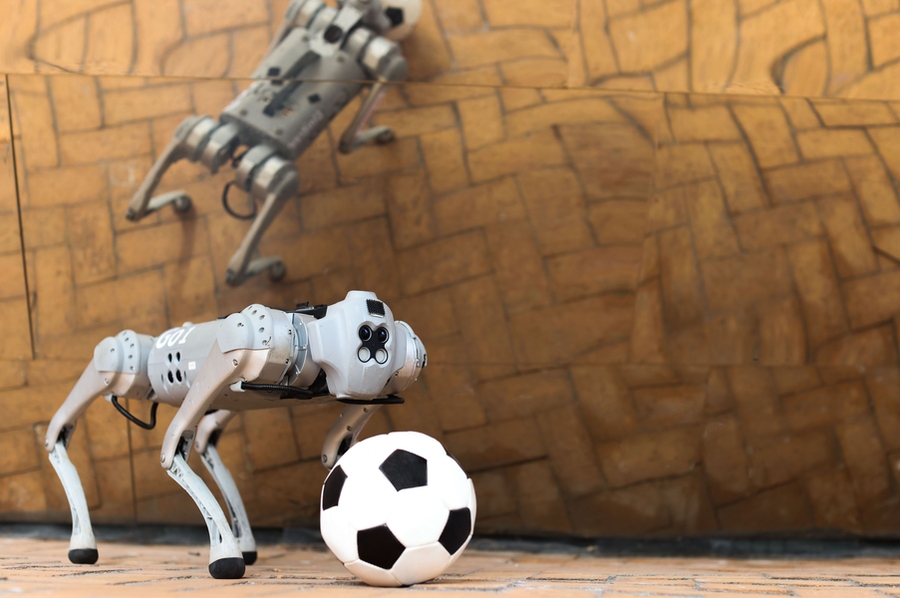
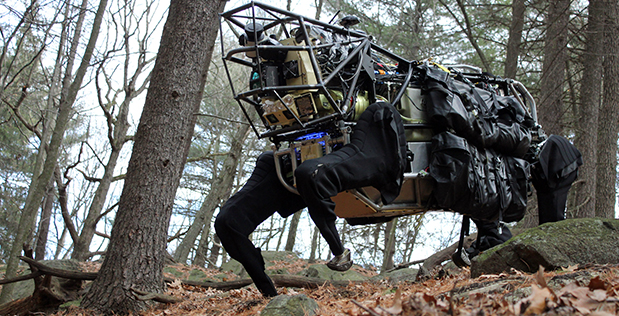
The researchers aim to use legged walking robots in challenging and complex terrains, such as those encountered in search-and-rescue missions. Legged robots have the advantage of being able to traverse terrains that are inaccessible to wheeled robots, which are limited by their need for flat surfaces.
"If you look around today, most robots are wheeled. But imagine that there's a disaster scenario, flooding, or an earthquake, and we want robots to aid humans in the search-and-rescue process. We need the machines to go over terrains that aren't flat, and wheeled robots can't traverse those landscapes." says Pulkit Agrawal, MIT professor, CSAIL principal investigator, and director of Improbable AI Lab.
"The whole point of studying legged robots is to go terrains outside the reach of current robotic systems...Our goal in developing algorithms for legged robots is to provide autonomy in challenging and complex terrains that are currently beyond the reach of robotic systems," Agrawal continued.
Programming walking robots to play soccer has been an active research area for some time, but the team wanted to automatically learn how to actuate the legs during dribbling, enabling the discovery of hard-to-script skills for responding to diverse terrains like snow, gravel, sand, grass, and pavement.
How DribbleBot Works & Current Challenges
To achieve this, the researchers used a simulation to create a digital twin of the natural world. A digital twin is a virtual representation of a physical object, process, or system that is created using data from sensors, cameras, and other sources. It's essentially a digital replica of the physical object, which can be used for various purposes, such as design, testing, optimization, and maintenance.
They loaded the robot, ball, and terrain into the simulation and set physics parameters, allowing them to handle the forward simulation of the dynamics. Four thousand versions of the robot were simulated in parallel in real time, enabling data collection 4,000 times faster than using just one robot.
The robot has a set of sensors that let it perceive the environment, allowing it to feel where it is, "understand" its position, and "see" some of its surroundings. It has a set of actuators that lets it apply forces and move itself and objects. In between the sensors and actuators sits the computer, or "brain," tasked with converting sensor data into actions, which it will apply through the motors. When the robot is running on snow, it doesn't see the snow but can feel it through its motor sensors. But soccer is a trickier feat than walking — so the team leveraged cameras on the robot's head and body for a new sensory modality of vision, in addition to the new motor skill.
However, there are still challenges involved in making these robots as agile as their counterparts in nature, and some terrains were challenging for DribbleBot. Currently, the controller is not trained in simulated environments that include slopes or stairs. The robot isn't perceiving the geometry of the terrain; it's only estimating its material contact properties, like friction. If there's a step up, for example, the robot will get stuck — it won't be able to lift the ball over the step, an area the team wants to explore in the future.
The development of DribbleBot is an impressive demonstration of the feasibility of legged robotic systems in a complex problem space that requires dynamic whole-body control. The researchers aim to apply lessons learned during the development of DribbleBot to other tasks that involve combined locomotion and object manipulation, such as quickly transporting diverse objects from place to place using the legs or arms.
Why This Matters
The research is supported by the DARPA Machine Common Sense Program, the MIT-IBM Watson AI Lab, the National Science Foundation Institute of Artificial Intelligence and Fundamental Interactions, the U.S. Air Force Research Laboratory, and the U.S. Air Force Artificial Intelligence Accelerator.
Key funder DARPA, or Defense Advanced Research Projects Agency, is an agency of the US Department of Defense responsible for the development of emerging technologies for military use. DARPA has funded many notable projects that have had significant impacts on the world. Some of the most famous projects funded by DARPA include Global Positioning System (GPS), Stealth technology, and Autonomous vehicles to name a few.
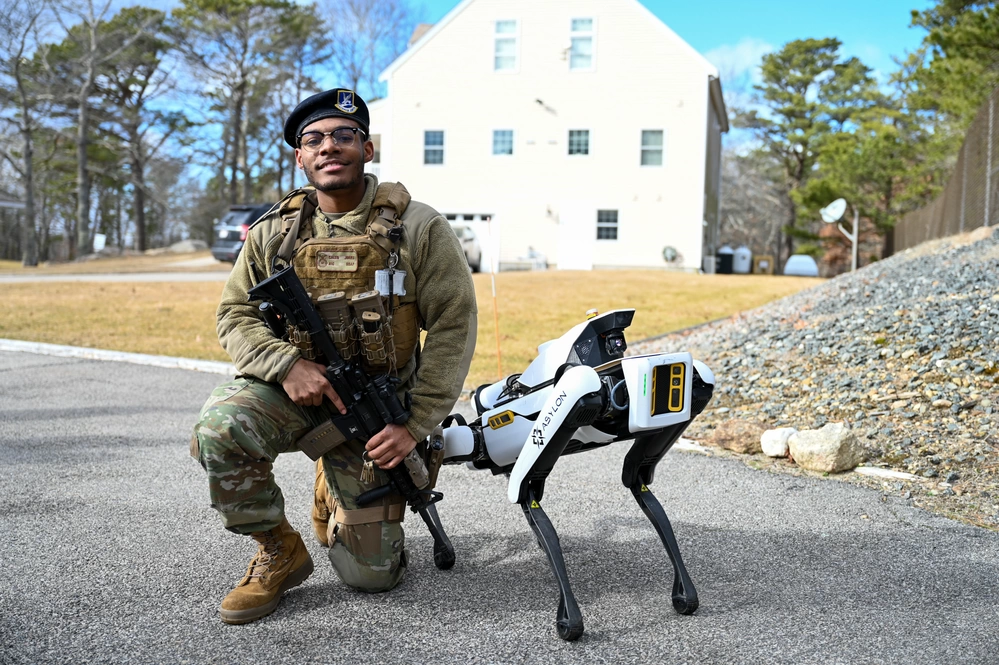
Just like the UAVs and drones used on the battlefield today, military robot dogs have the potential to enhance military operations by providing advanced sensing and mobility capabilities, improving soldier safety, and enabling soldiers to focus on other critical tasks.

Some key areas where military robot dogs could serve:
- Search and rescue: In disaster or combat zones, robot dogs can be used to search for and locate missing or injured soldiers or civilians.
- Surveillance and reconnaissance: Military robot dogs equipped with advanced sensors and cameras can be used to gather intelligence and conduct surveillance missions in areas that are difficult or dangerous for human soldiers to access.
- Detection of explosives and hazardous materials: Robot dogs equipped with sensors and detectors can be used to detect explosives and other hazardous materials, helping to keep soldiers safe from harm.
- Logistics and supply: Military robot dogs can be used to transport supplies and equipment over rough terrain, freeing up human soldiers to focus on other critical tasks.
- Perimeter defense: Robot dogs can be used to patrol and secure perimeters, detecting intruders and alerting human soldiers of potential threats.